Data format
For engineers. One site file goes in. For every simulated shift, one label record and four logs come out. A shift is fixed by its site file, policy, seed and fault schedule, so any label can be regenerated.
What you send
Robot types, a site map and a task list in one YAML file. This is an excerpt of the earthworks yard.
robot_types:                     # 1. your robots
  hauler: {caps: [TRANSPORT, PLACE], speed: 0.22, radius: 0.18}
fleet:
  - {name: Haul1, type: hauler, spawn: [-1.5, -1.0], depot: [-2.6, -0.5]}

obstacles:                       # 2. your site
  - {id: berm_north, rect: [0.15, 2.05, 0.45, 4.0], kind: berm}
aisles:
  - {id: north_gate, rect: [-0.45, 1.25, 1.05, 2.05],
     ends: [[-0.75, 1.65], [1.35, 1.65]]}

tasks:                           # 3. your task list, with precedence
  - {id: 2, label: dig trench A, cap: EXCAVATE,
     world: [1.7, 2.1], duration: 6.0, requires: [0]}
  - {id: 4, label: haul spoil A, cap: TRANSPORT,
     world: [2.4, 2.5], dest: [-1.0, 3.0], requires: [2]}
What comes back
Per shift. The mission log and the evaluator's truth are separate files on purpose.
labels.jsonWhat failed, which decision detected it and which answered it, whether the fleet recovered, and the delay against the same shift with no fault.decisions.jsonlEvery coordinator decision, numbered in order, with the other robots and tasks it could have chosen.events.jsonlThe mission log the coordinator could have written itself. No injected truth in it.truth.jsonlFor the evaluator only: injections, health changes, and work that was physically done.timestep.csvPose, speed, state and nearest neighbour for every robot at 10 Hz.frames/Isaac Sim runs only: RTX frames and a ground-truth record per frame.
A label record
The run “A hauler dies mid-task” from the replay, schema auton.shift_label/1. Download the whole run.
{
 "schema": "auton.shift_label/1",
 "run_id": "yard-robot-death",
 "site": "construction_yard",
 "env_seed": 1,
 "fleet": [
  {
   "name": "Exc1",
   "role": "EXCAVATOR",
   "caps": [
    "EXCAVATE",
    "PLACE"
   ]
  },
  {
   "name": "Exc2",
   "role": "EXCAVATOR",
   "caps": [
    "EXCAVATE",
    "PLACE"
   ]
  },
  {
   "name": "Haul1",
   "role": "HAULER",
   "caps": [
    "PLACE",
    "TRANSPORT"
   ]
  },
  {
   "name": "Haul2",
   "role": "HAULER",
   "caps": [
    "PLACE",
    "TRANSPORT"
   ]
  },
  {
   "name": "Surv1",
   "role": "SURVEYOR",
   "caps": [
    "INSPECT"
   ]
  }
 ],
 "n_tasks": 16,
 "policy": {
  "name": "baseline",
  "allocator": "greedy",
  "heartbeat_timeout_s": 6,
  "stuck_secs": 8,
  "block_patience_s": 3,
  "conflict_resolve_s": 2,
  "deadlock_detect_s": 6,
  "deadlock_policy": "pull_over",
  "blocked_escalate_s": 45,
  "degraded_detect_ratio": 0.6,
  "stamp_downed": true
 },
 "engine": {
  "backend": "kinematic",
  "dt_s": 0.1,
  "traffic": true,
  "allocator": "greedy"
 },
 "injected": [
  {
   "fault_id": "f1",
   "type": "robot_death",
   "t": 130,
   "agent": "Haul1",
   "params": {}
  }
 ],
 "outcome": {
  "mission": "COMPLETE",
  "tasks_done": 16,
  "tasks_total": 16,
  "tasks_never_completed": [],
  "makespan_s": 415.7,
  "sim_end_s": 415.8,
  "robots_lost": [
   "Haul1"
  ],
  "fleet_recovered": true,
  "distance_m": 161.74,
  "nominal_makespan_s": 374.9,
  "delay_s": 40.8
 },
 "faults": [
  {
   "fault_id": "f1",
   "type": "robot_death",
   "title": "Robot dies mid-task",
   "agent": "Haul1",
   "agents": null,
   "t_inject": 130,
   "t_end": null,
   "params": {},
   "context": {
    "agent_state": "enroute",
    "task": "T5",
    "pos": [
     -1.69,
     -0.96
    ],
    "aisle": null,
    "role": "HAULER"
   },
   "manifested": true,
   "detection": {
    "detected": true,
    "t": 136,
    "latency_s": 6,
    "latent_s": 0,
    "by": "heartbeat_timeout",
    "decision_id": "d0023",
    "diagnosis": {
     "believed": "down",
     "truth": "dead",
     "correct": true
    }
   },
   "response_decisions": [
    "d0023",
    "d0025"
   ],
   "decisive_decision": "d0025",
   "recovery": {
    "recovered": true,
    "t": 212,
    "latency_s": 82,
    "how": "T5 finished by Haul2",
    "displaced_tasks": [
     "T5"
    ],
    "unrecovered_tasks": []
   },
   "incidents": []
  }
 ],
 "incidents": [],
 "summary": "Haul1 died at 130 s while driving to T5. The coordinator caught it 6.0 s after onset from missing heartbeats. Recovered: yes (T5 finished by Haul2). All 16 tasks finished, +41 s against the fault-free shift.",
 "counts": {
  "decisions": 42,
  "events": 75,
  "by_event": {
   "DISPATCH": 16,
   "COLLISION_RISK": 13,
   "REROUTE": 5,
   "ARRIVE": 22,
   "COMPLETE": 16,
   "PRESUMED_DOWN": 1,
   "REASSIGN": 2
  }
 },
 "meta": {}
}
The fault catalog
Each entry states what it leaves out. Catalog and campaign summaries as JSON.
robot_deathNo coast-down or partial power; the body stops within one control step.immobilizedBinary traction loss; no partial slip or digging-in dynamics.degraded_speedA flat speed cap; no load-dependent or thermal behaviour.capability_lossThe tool fails completely; no reduced-payload or slow-cycle mode.intermittent_dropoutClean edges; no brownout, no corrupted state on resume.comms_lossWhole-link outage; no packet loss rate, latency or range model.blocked_pathAxis-aligned box; appears and clears instantly.aisle_contentionThe contention is staged by the injector. Whether it becomes a deadlock, and whether the fleet gets out of it, is decided by the policy under test.
One frame and its ground truth
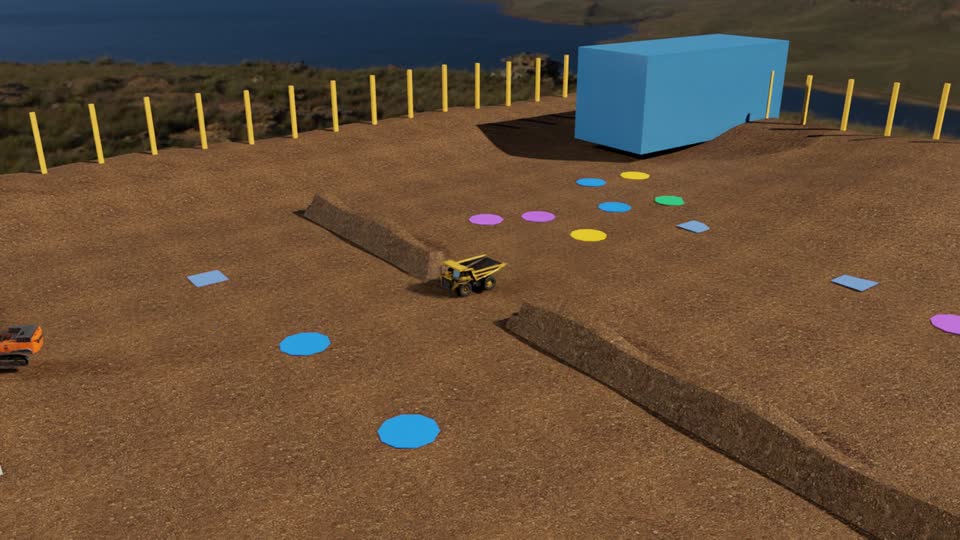
{
 "t": 150,
 "robots": {
  "Exc1": {
   "x": -0.125,
   "y": -1.62,
   "yaw": 2.243,
   "state": "returning",
   "task": null,
   "flags": ""
  },
  "Exc2": {
   "x": -2.416,
   "y": 2.42,
   "yaw": 2.738,
   "state": "idle",
   "task": null,
   "flags": ""
  },
  "Haul1": {
   "x": -2.419,
   "y": -0.642,
   "yaw": -0.522,
   "state": "enroute",
   "task": "T5",
   "flags": "DX"
  },
  "Haul2": {
   "x": 0.245,
   "y": 1.77,
   "yaw": -3.091,
   "state": "hauling",
   "task": "T4",
   "flags": ""
  },
  "Surv1": {
   "x": -2.581,
   "y": 0.484,
   "yaw": 2.343,
   "state": "idle",
   "task": null,
   "flags": ""
  }
 },
 "active_faults": [
  "f1"
 ],
 "tasks_done": 7,
 "frame": 374,
 "files": {
  "lane": "frame.jpg"
 }
}
Reproduce the campaigns
Python 3.9 or newer and PyYAML. Seeded, so the same command gives the same labels.
python3 -m faultlib.campaign --site construction_yard --shifts 3000 --seed 42 --out campaigns/faultlib_yard --keep 8
python3 -m faultlib.campaign --site warehouse_aisles --shifts 3000 --seed 42 --out campaigns/faultlib_warehouse --keep 8
python3 -m unittest tests.test_faultlib